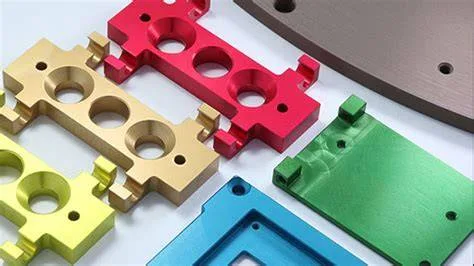
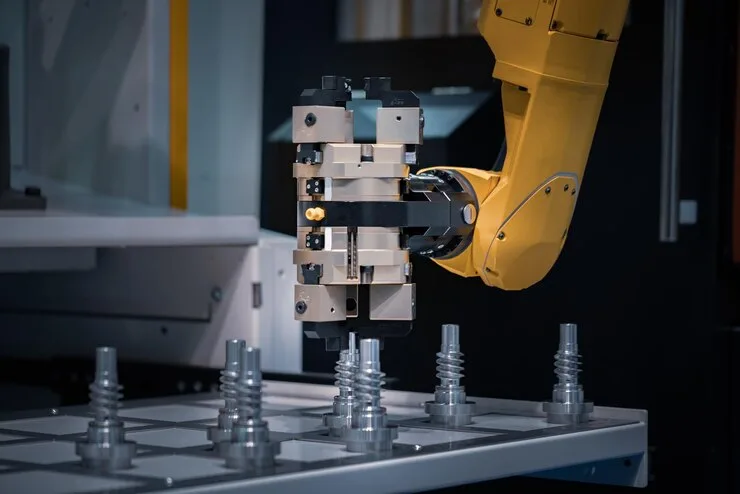
Precision Robotic Parts Machining
The Precision Foundation of Automation: Advanced CNC Machining for Robotic Components
Introduction: The Critical Role of Precision Manufacturing in Robotic Evolution
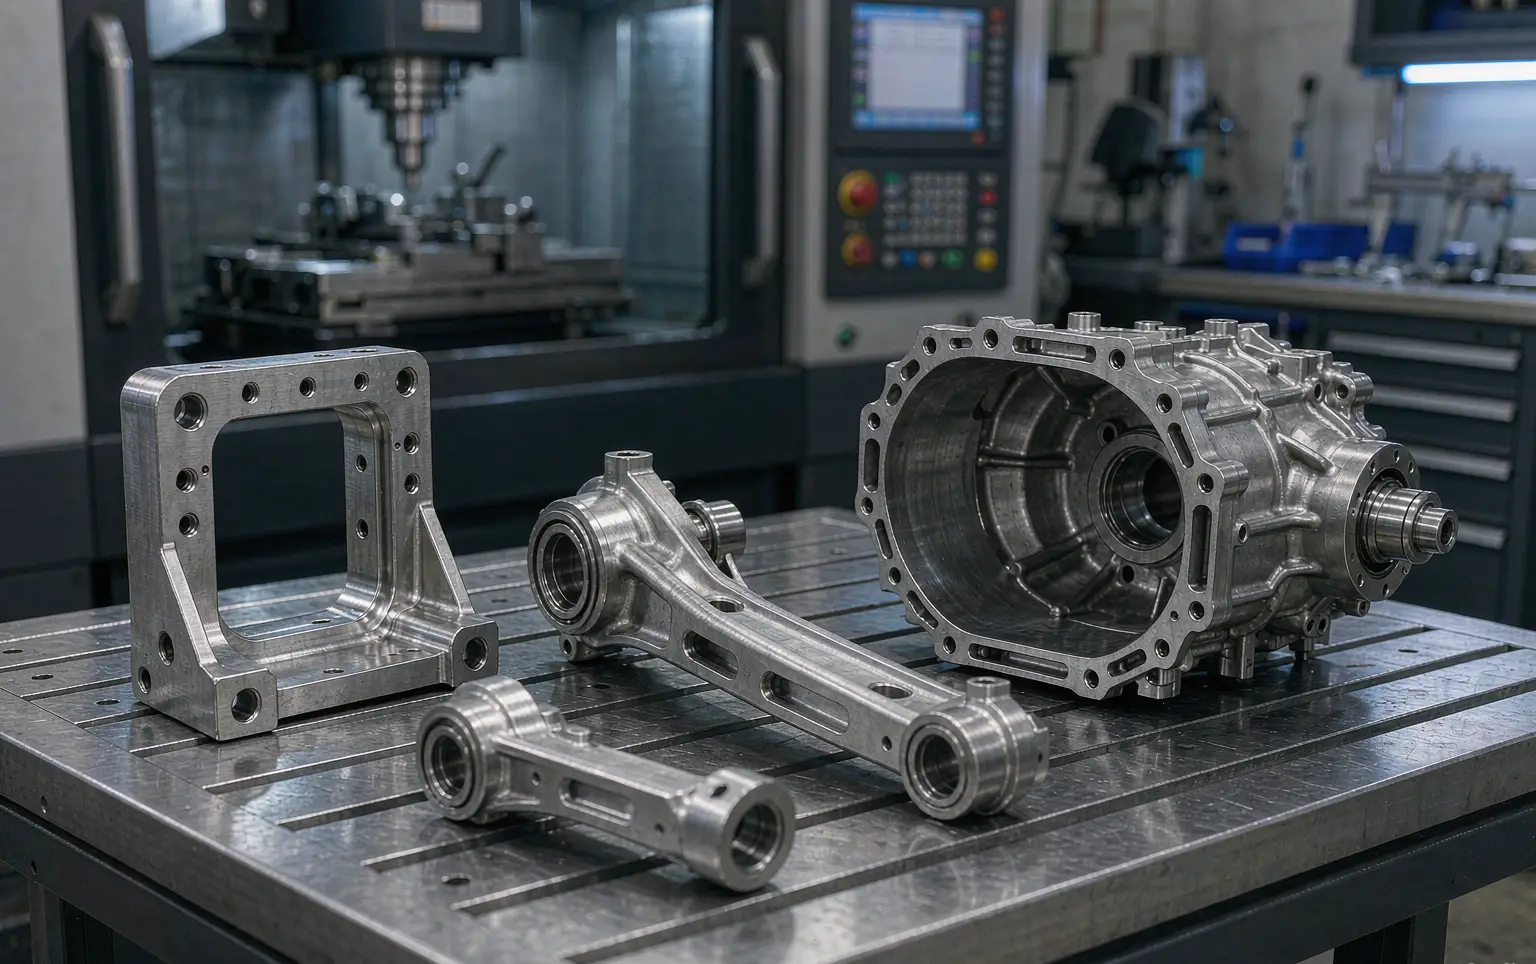
In the field of modern industrial automation, the performance ceiling of any robotic system is determined long before software optimization or sensor integration, it is fundamentally established during the manufacturing of its mechanical components. Robotic Parts Machining represents a specialized discipline at the intersection of precision engineering, advanced materials science, and multi-axis manufacturing, where tolerances are measured in microns, structural dynamics are engineered into the material, and geometric complexity must serve functional imperatives. At JLYPT, we operate within this critical niche, transforming engineering specifications for robotic arms, end effectors, and motion systems into physical components that deliver deterministic performance across millions of operational cycles.
The distinction between conventional machining and precision robotic parts machining manifests in measurable system-level outcomes: a 0.005mm improvement in bearing seat concentricity can reduce transmission backlash by 40%; a strategically engineered internal lattice can increase structural stiffness by 60% while reducing mass; and a surface finish improvement from Ra 0.8µm to Ra 0.2µm can extend harmonic drive service life by 300%. These are not incremental gains but transformative improvements that enable robots to perform delicate assembly tasks, execute high-speed pick-and-place operations with micron-level repeatability, and operate continuously in demanding industrial environments without degradation. This manufacturing discipline requires understanding not just how to remove material efficiently, but how to engineer the resulting component’s interaction with forces, motions, and environmental factors unique to robotic operation.
This comprehensive examination details the technical methodologies, material strategies, and validation protocols that define modern robotic component manufacturing. We will analyze why specialized aluminum alloys and vacuum-treated steels are specified for different robotic subsystems, how 5-axis simultaneous machining enables consolidated joint assemblies, and what metrological approaches verify that kinematic performance matches computational models. For engineers developing collaborative robots for sensitive human interaction, high-speed delta robots for packaging, or specialized robotic systems for surgical applications, this knowledge forms the essential bridge between theoretical design and reliable operation. Discover how our specialized capabilities in precision robotic parts machining provide the mechanical foundation upon which advanced automation systems are built.
The Mechanical Imperatives: Unique Requirements for Robotic Components
Robotic systems impose a distinct set of mechanical requirements that differentiate them from conventional machinery components. These requirements drive every aspect of the manufacturing process from initial material selection through final quality validation.
Kinematic Accuracy and Error Stack-Up Mitigation
Robotic systems function as kinematic chains where the position and orientation of the end-effector result from the cumulative positioning of each joint in the serial linkage. This creates a critical manufacturing challenge: error stack-up. A minute angular deviation at the base joint or a tiny parallelism error in a link translates to magnified positional inaccuracy at the end of the arm. Consequently, robotic parts demand exceptional geometric tolerances:
Bearing seat concentricity and perpendicularity typically within 0.008mm (0.0003″)
Bore true position tolerances often held to 0.01mm (0.0004″)
Flatness of mounting surfaces frequently specified at 0.01mm per 100mm
Pitch circle accuracy for gear and timing pulley mounts within 0.005mm
Dynamic Performance and Vibration Control
High-speed robotic operation generates significant dynamic forces that challenge structural integrity and precision. Components must be engineered for:
High natural frequencies to avoid resonance with operational vibration spectra (typically requiring first structural mode > 150Hz for industrial arms)
Optimal damping characteristics to dissipate vibrational energy without adding excessive mass
Balanced rotating assemblies to minimize induced vibrations from motors and transmissions
Controlled stiffness-to-weight ratios that maximize acceleration capabilities while maintaining precision under load
Cyclic Loading and Fatigue Life
Industrial robots routinely execute millions of motion cycles, creating demanding fatigue environments:
High-cycle fatigue resistance exceeding 10⁷ cycles at operational stress levels
Surface integrity that minimizes stress concentration points that initiate cracks
Material homogeneity that prevents inclusion-initiated failure in highly stressed areas
Residual stress management from manufacturing processes that could accelerate fatigue
Thermal Stability in Precision Systems
Robotic accuracy must be maintained across operational temperature ranges as heat generates from:
Servo motor operation (particularly in compact joint designs)
Transmission inefficiencies in gearboxes and reducers
Environmental fluctuations in manufacturing facilities
Friction in linear motion components
This necessitates materials with low coefficients of thermal expansion, designs that accommodate thermal growth, and manufacturing processes that ensure dimensional stability across temperature ranges.
Table 1: Robotic Component Performance Requirements vs. Manufacturing Solutions
Performance Parameter
Robotic System Requirement
Conventional Machining Limitation
Precision Robotic Parts Solution
Positional Accuracy
End-effector repeatability ≤ 0.02mm
Tolerance stack-up from multiple setups
Single-setup 5-axis machining; In-process verification
Dynamic Stiffness
High natural frequency (>150Hz); Minimal vibration
Limited thin-wall capability; Isotropic material properties
Topologically optimized structures; Directional reinforcement
Cyclic Durability
>10⁷ cycle operational life without degradation
Surface imperfections acting as stress concentrators
Superfinished surfaces (Ra ≤ 0.2µm); Controlled residual stresses
Thermal Stability
≤ 0.01mm drift across 20°C temperature range
Uncontrolled thermal expansion; Inhomogeneous materials
Low-CTE alloys; Symmetrical thermal design; Stress-relieving processes
Backlash Minimization
≤ 0.005mm transmission backlash for precision tasks
Conventional bearing fits; Assembly-induced misalignment
H6/g5 or tighter bearing fits; Integrated preload mechanisms
Mass Optimization
Maximum acceleration with given actuator capabilities
Prismatic designs with high safety factors
Generative design algorithms; Thin-wall machining (≥0.5mm walls)
Material Science for Robotic Applications
The selection of engineering materials for robotic components represents a critical decision point that balances mechanical properties, manufacturability, environmental factors, and economic considerations.
Aluminum Alloys for Structural Components
7075-T6 Aluminum: The premier choice for high-performance robotic structures requiring maximum strength-to-weight ratios. With tensile strength approaching 570 MPa and excellent machinability, this alloy enables thin-wall construction that maintains stiffness while minimizing moving mass. Applications include robot arm links, joint housings, and end-effector structures where dynamic performance is paramount.
6061-T6 Aluminum: Provides excellent all-around properties for less critically loaded components, offering good machinability, weldability, and corrosion resistance at lower cost. Typical applications include protective covers, mounting brackets, and enclosures where extreme strength is not required.
Cast Aluminum Alloys (A356-T6): Used for complex housings where near-net-shape casting reduces machining requirements. Typically requires precision CNC machining for critical interfaces and bearing surfaces to achieve required tolerances.
Steel Alloys for High-Strength Applications
4140/4340 Alloy Steel (Heat Treated): Delivers exceptional strength (up to 1,380 MPa yield) for gears, shafts, and high-stress connections in heavy-payload robots. Requires careful heat treatment management to minimize distortion, with final machining often performed after hardening using grinding or hard turning processes.
Stainless Steel (304, 316, 17-4PH): Essential for food-grade, medical, and corrosive environment robotics. 17-4PH (precipitation hardening stainless) offers the unique advantage of being machined in a soft condition then age-hardened to approximately 44 HRC with minimal dimensional change.
Tool Steels (D2, A2, M2): Used for wear surfaces, cutting tool interfaces, and high-abrasion components in specialized robotic applications. These materials require specialized machining approaches and typically undergo heat treatment to achieve working hardness levels.
Specialized Alloys for Demanding Applications
Titanium (Ti-6Al-4V): Provides exceptional strength-to-weight ratio and corrosion resistance for aerospace and medical robotic applications. Despite challenging machinability and higher cost, its performance justifies use in critical components.
Invar (Fe-Ni36%): Offers extremely low coefficient of thermal expansion (CTE ≈ 1.2 × 10⁻⁶/°C) for metrology frames and precision reference structures where thermal stability is paramount.
Magnesium Alloys: While less common due to corrosion and flammability concerns, magnesium provides the highest strength-to-weight ratio of commonly machined metals for applications where minimal mass is critical.
Engineering Polymers and Composites
PEEK (Polyetheretherketone): High-performance thermoplastic offering excellent strength, chemical resistance, and thermal stability for insulating components, low-friction bushings, and vacuum-compatible parts.
VESPEL (Polyimide): Used in extreme temperature applications where conventional polymers fail, with continuous service up to 260°C (500°F).
Carbon Fiber Reinforced Composites: Provide exceptional stiffness-to-weight ratios and damping characteristics for long robot arms and high-speed components where minimizing deflection and vibration is critical.
Table 2: Material Selection Matrix for Robotic Components
Component Type
Primary Requirements
Optimal Materials
Alternative Options
Key Manufacturing Considerations
Robot Arm Links
High stiffness/weight; Fatigue resistance; Damping
7075-T6 Aluminum; Carbon Fiber Composites
6061-T6; Titanium (premium)
Thin-wall machining; Topological optimization; Vibration damping features
Joint Housings
Bearing seat precision; High strength; Thermal stability
7075-T6 Aluminum; Ductile Iron (large)
6061-T6; Steel castings
Bore concentricity (≤0.008mm); Preload management; Heat dissipation
Gears & Transmission
Wear resistance; High strength; Precision tooth form
4140 Steel (hardened); Powdered metals
8620 Steel; Bronze (wear surfaces)
Post-hardening grinding; Tooth profile accuracy; Surface finishing
Linear Guide Components
Wear resistance; Dimensional stability; Smooth motion
1045 Steel (hardened & ground); Aluminum with inserts
Stainless steel; Engineering polymers
Grinding to precision tolerances; Straightness control; Surface finish (Ra ≤ 0.4µm)
End-Effector Jaws
Gripping force; Wear resistance; Low inertia
Tool steel (D2, A2); Aluminum with hard coating
Titanium; Engineering polymers
Hardening after machining; Surface treatments; Mass optimization
Sensor Mounts
Vibration isolation; Dimensional stability; Low CTE
Invar; 6061-T6 with isolation
Magnesium; Engineering polymers
Micro-machining for alignment features; Vibration damping integration
Base Structure
Rigidity; Vibration damping; Mass
Granite composite; Welded steel with stress relief
Cast iron; Concrete-filled steel
In-situ machining of mounting surfaces; Vibration damping design
Advanced Machining Technologies for Robotic Components
Meeting the stringent requirements of robotic parts necessitates specialized machining technologies beyond conventional 3-axis milling.
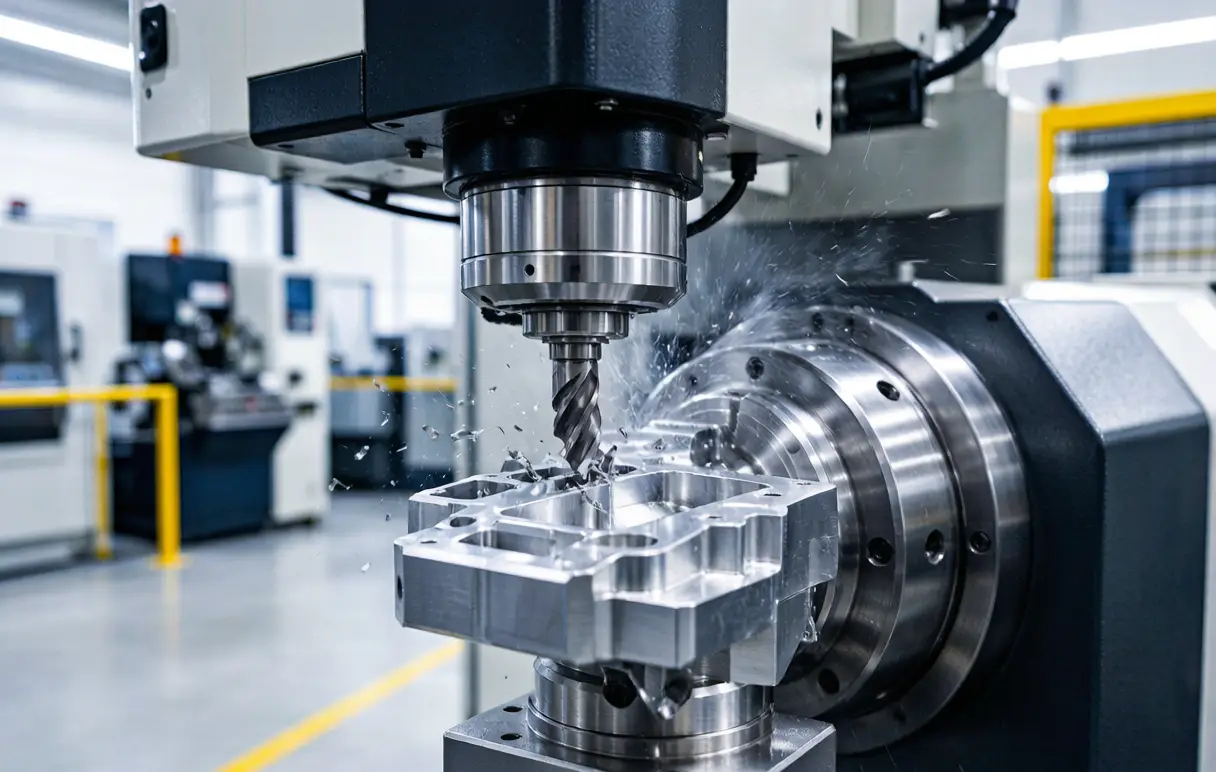
5-Axis Simultaneous Machining
This technology enables machining of complex robotic components from multiple angles in a single setup, providing critical advantages:
Complex geometry capability for consolidated joint assemblies and optimized structural shapes
Improved accuracy by eliminating multiple setups that introduce tolerance stack-up
Superior surface finish through optimal tool orientation and continuous tool engagement
Reduced lead times by completing parts in fewer operations
Micromachining for Precision Features
Many robotic components require exceptionally fine features that demand specialized micromachining capabilities:
Small diameter tools (down to 0.1mm/0.004″) for complex channels and fine details
High spindle speeds (up to 60,000 RPM) for proper cutting speeds with micro-tools
Advanced toolpath strategies to prevent tool deflection and breakage
Sub-micron positioning for feature accuracy and surface finish
Hard Turning and Grinding
For components requiring exceptional hardness and precision after heat treatment:
Hard turning of materials up to 62 HRC using cubic boron nitride (CBN) or polycrystalline cubic boron nitride (PCBN) inserts
Precision grinding for the highest accuracy surfaces, achieving tolerances to 0.001mm (0.00004″) and surface finishes to Ra 0.1µm
Centerless grinding for high-volume production of shafts and pins with exceptional roundness and diameter control
Ultrasonic Assisted Machining
Applying ultrasonic vibration during cutting processes provides significant benefits for challenging robotic materials:
Reduced cutting forces (30-70% reduction) enabling thinner walls and more delicate features
Improved surface finish through altered chip formation mechanisms
Extended tool life particularly with difficult-to-machine alloys like titanium and Inconel
Minimized workpiece distortion through reduced cutting forces and temperatures
Quality Assurance and Metrology for Robotic Parts
The precision requirements of robotic components demand comprehensive quality assurance methodologies throughout the manufacturing process.
First Article Inspection (FAI)
Complete dimensional validation against design specifications using:
Coordinate Measuring Machines (CMM) with volumetric accuracy ≤ 0.001mm + L/350µm
Laser scanning for complex surface verification
Optical comparators for profile verification
Surface roughness measurement with profilometers
In-Process Verification
Real-time quality assurance during manufacturing:
On-machine probing for feature verification between operations
Tool condition monitoring to ensure cutting edge integrity
Adaptive control systems that adjust parameters based on real-time feedback
Statistical process control (SPC) tracking critical dimensions through production runs
Non-Destructive Testing (NDT)
Ensuring material integrity without compromising components:
Dye penetrant inspection (DPI) for surface-breaking defect detection
X-ray inspection for internal void and inclusion detection
Ultrasonic testing for bond integrity and material consistency
Eddy current testing for surface and near-surface defect detection
Functional Testing
Validating performance under simulated operating conditions:
Runout and concentricity testing for rotating assemblies
Backlash measurement in gear trains and transmission systems
Stiffness testing under simulated operational loads
Vibration testing to verify dynamic characteristics
Table 3: Robotic Component Quality Standards and Validation Methods
Component Category
Critical Quality Parameters
Measurement Methods
Acceptance Standards
Bearing Housings
Bore diameter (H6/H7); Concentricity; Surface finish
CMM; Air gaging; Surface profilometer
ISO 286 H6/H7; Concentricity ≤ 0.008mm; Ra ≤ 0.4µm
Precision Shafts
Diameter (g5/g6); Straightness; Surface finish
Micrometer; Laser micrometer; Roundness tester
ISO 286 g5/g6; Straightness ≤ 0.005mm/100mm; Ra ≤ 0.2µm
Gear Components
Tooth profile; Pitch accuracy; Surface finish
Gear analyzer; CMM with gear software; Surface profilometer
AGMA 2000-A88 Class 10+; Pitch error ≤ 0.005mm; Ra ≤ 0.4µm
Structural Frames
Flatness; Hole pattern accuracy; Squareness
CMM; Laser tracker; Precision level
Flatness ≤ 0.01mm/100mm; Position tolerance ≤ 0.02mm; Squareness ≤ 0.005mm/100mm
Linear Guide Rails
Straightness; Parallelism; Surface finish
Autocollimator; Precision level; Surface profilometer
Straightness ≤ 0.003mm/100mm; Parallelism ≤ 0.005mm; Ra ≤ 0.2µm
Rotary Unions
Concentricity; Face runout; Surface finish
CMM; Dial indicator; Surface profilometer
Concentricity ≤ 0.005mm; Face runout ≤ 0.003mm; Ra ≤ 0.2µm
Case Studies: Precision Manufacturing Solutions for Robotic Applications
Case Study 1: Collaborative Robot (Cobot) Forearm Assembly
Challenge: A cobot manufacturer required a forearm assembly that maximized payload capacity while maintaining the stiffness necessary for precision tasks and providing integrated cable routing for power and data transmission.
Solution: We designed and manufactured a monolithic forearm housing from 7075-T6 aluminum using 5-axis simultaneous machining:
Topologically optimized structure achieving 40% weight reduction while increasing torsional stiffness by 25%
Integrated cable channels with smooth radii to prevent cable wear during articulation
Precision bearing seats with 0.006mm concentricity for smooth joint operation
Hardcoat anodized surfaces at wear points for extended service life
Results: The forearm assembly enabled a 15% increase in maximum payload capacity while maintaining 0.02mm end-effector repeatability. Integrated cable routing eliminated external cabling, improving safety and reliability in collaborative environments.
Case Study 2: High-Speed Delta Robot Central Platform
Challenge: A packaging automation company needed a central moving platform for a high-speed delta robot capable of 300 picks per minute with 0.01mm repeatability.
Solution: We precision-machined the platform from solid 7075-T6 aluminum using single-setup 5-axis machining:
Three pairs of bearing seats machined in one setup ensuring perfect mutual parallelism (≤0.005mm) and angular position
Kinematic coupling features for precise, repeatable end-effector mounting
Dynamic balancing to 0.1g·mm residual imbalance at operating speed
Mass optimization removing 30% material while maintaining structural integrity
Results: The platform achieved 0.008mm measured repeatability at 300 picks/minute, exceeding design requirements. Dynamic balancing eliminated high-frequency vibration that had previously limited operational speed in earlier designs.
Case Study 3: Surgical Robot Wrist Mechanism
Challenge: A medical device company required a miniature robotic wrist mechanism providing two degrees of freedom within a 10mm diameter envelope for minimally invasive surgical applications.
Solution: We employed micro-machining techniques with specialized equipment:
Titanium (Ti-6Al-4V ELI) components for biocompatibility and strength
Micro-gears with module 0.15 and precision bearing surfaces
Single-micron tolerances on critical features
Electropolished surfaces for biocompatibility and cleanability
Results: The wrist mechanism provided smooth, backlash-free motion through ±90° articulation with 0.01° repeatability. The complete assembly met sterilization requirements and performed successfully in preclinical trials.
Future Directions in Robotic Parts Manufacturing
The field of robotic component manufacturing continues to evolve with several emerging trends:
Additive Manufacturing Integration
Complex internal channels for cooling, lubrication, and cable routing
Customized lattice structures for optimized stiffness-to-weight ratios
Multi-material components with localized property optimization
Reduced assembly through consolidated part design
Smart Manufacturing and Industry 4.0
Digital twins of manufacturing processes for predictive optimization
AI-driven process control adapting to material variations
Blockchain-enabled traceability for quality assurance documentation
Predictive maintenance based on manufacturing equipment monitoring
Sustainable Manufacturing Practices
Material efficiency optimization through advanced nesting algorithms
Energy consumption reduction through process optimization
Closed-loop material systems for recycling machining waste
Low-impact manufacturing processes minimizing environmental footprint
Conclusion: Manufacturing as the Foundation of Robotic Performance
The advancement of robotic technology is fundamentally constrained by the precision, reliability, and performance of its mechanical components. Robotic Parts Machining has evolved from a commodity manufacturing service to a specialized engineering discipline that directly determines the capabilities of automation systems. From material science through advanced processing to comprehensive validation, each aspect of the manufacturing process contributes to the ultimate performance of the robotic system.
At JLYPT, we recognize that robotic components are not merely mechanical parts but integral elements of sophisticated motion systems. Our approach combines deep technical expertise in precision manufacturing with understanding of robotic operational requirements, creating synergistic relationships between design intent and manufacturing execution.
Ready to advance your robotic system with precision manufacturing partnerships that understand your technical challenges? Contact our engineering team to discuss how our specialized machining services can transform your designs into reliable, high-performance robotic components. From prototype development through production manufacturing, we provide the precision foundation for advanced automation systems. Begin your project at JLYPT Precision Robotic Parts Machining.
If you are also evaluating CNC robotics precision manufacturing, aluminum drone parts manufacturer, or precision CNC machining for defense industry on the same drawing, the resources below extend this guide into those adjacent decisions.